|
Ege Yuceel Hi! I'm a third-year Ph.D. student in the Reliable Autonomy Group at the University of Illinois Urbana-Champaign (UIUC), advised by Prof. Sayan Mitra. My research interests lie in efficient planning algorithms, autonomy under limited information and resource constraints, with applications in aerial vehicles. Previously, I received my B.Sc. in Electrical and Electronics Engineering from Bilkent University, where I was fortunate enough to work with Dr. Muhammed Ömer Sayın in the Games, AI, and Networks Research Lab on multi-agent learning and game theory. |
|
News
|
Selected Work |
|
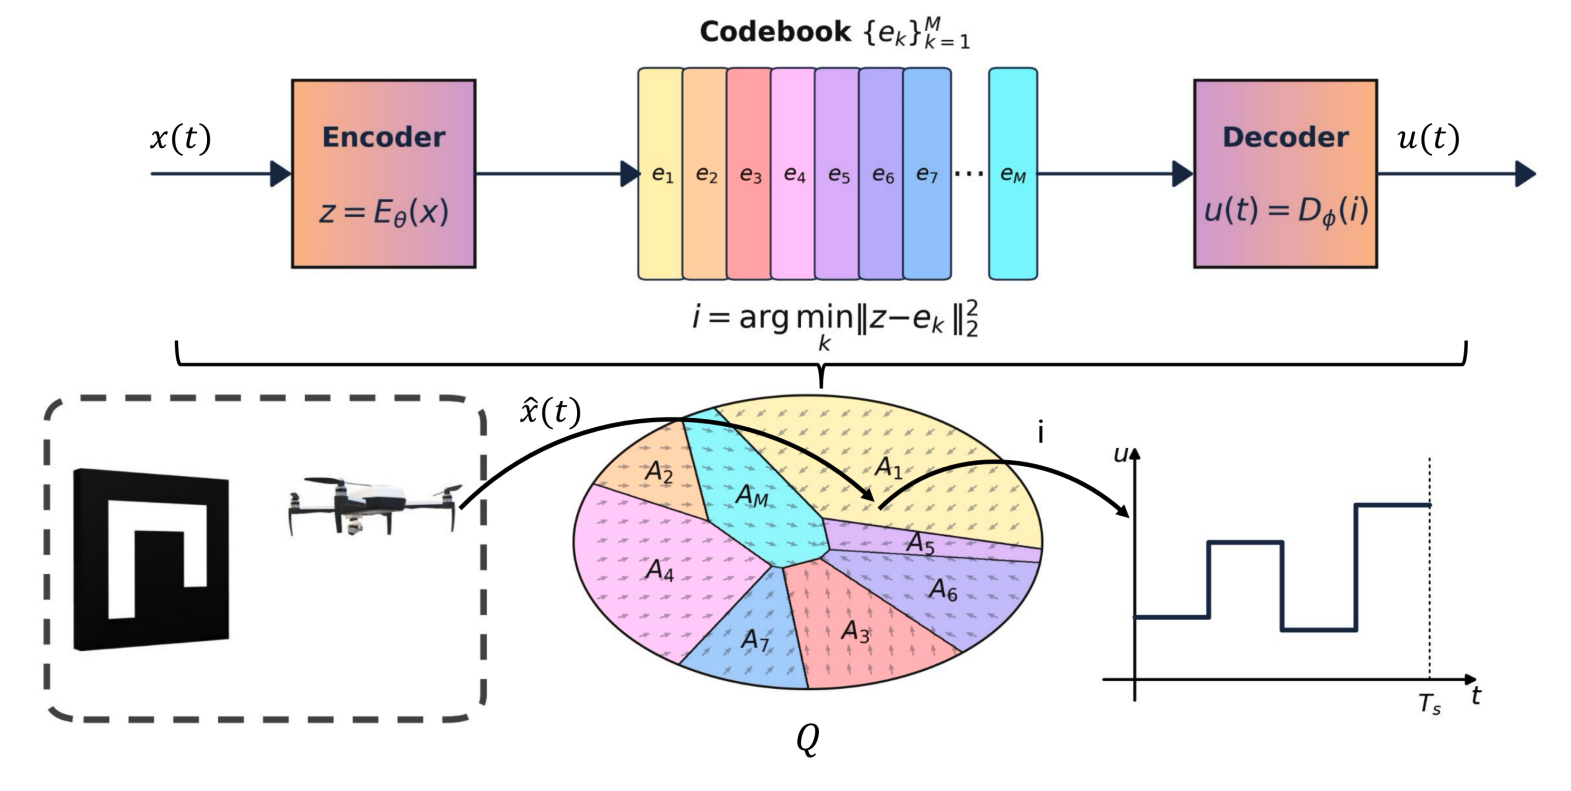
Minimal Information Control Invariance via Vector Quantization
Ege Yuceel, Teodor Tchalakov, Sayan Mitra IEEE Conference on Decision and Control (CDC), 2026 (To appear) Paper TL;DR: We propose a vector-quantized autoencoder that learns a minimal set of control regions keeping a system provably safe, linking how little information is needed to invariance entropy. On a 12D quadrotor it shrinks the codebook 157× against a uniform grid while a reachability certificate guarantees invariance. |
|
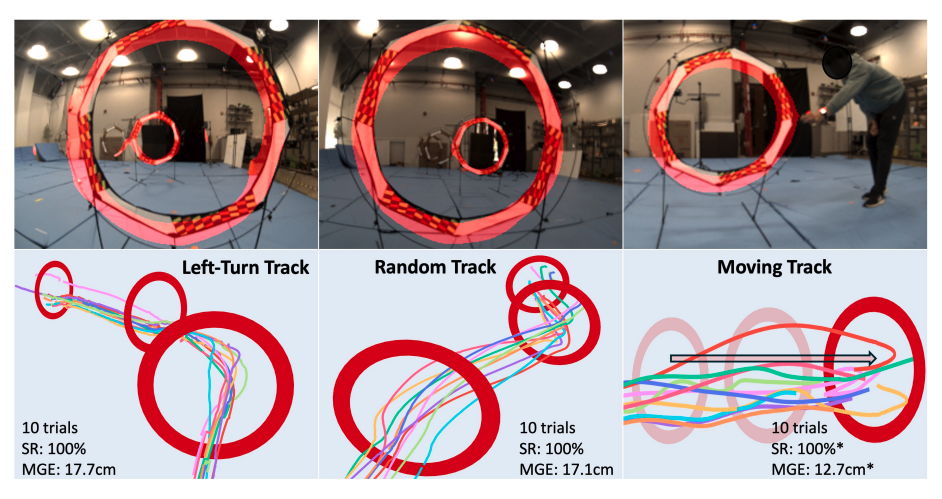
Performance-Guided Refinement for Visual Aerial Navigation using Editable Gaussian Splatting in FalconGym 2.0
Yan Miao, Ege Yuceel, Georgios Fainekos, Bardh Hoxha, Hideki Okamoto, Sayan Mitra IEEE International Conference on Robotics and Automation (ICRA), 2026 Paper TL;DR: We present FalconGym 2.0, an editable Gaussian-splatting simulator, with a Performance-Guided Refinement algorithm that trains a single visual flight policy on the hardest tracks. It reaches 100% success on unseen tracks and transfers zero-shot to real hardware at 98.6%. |
|
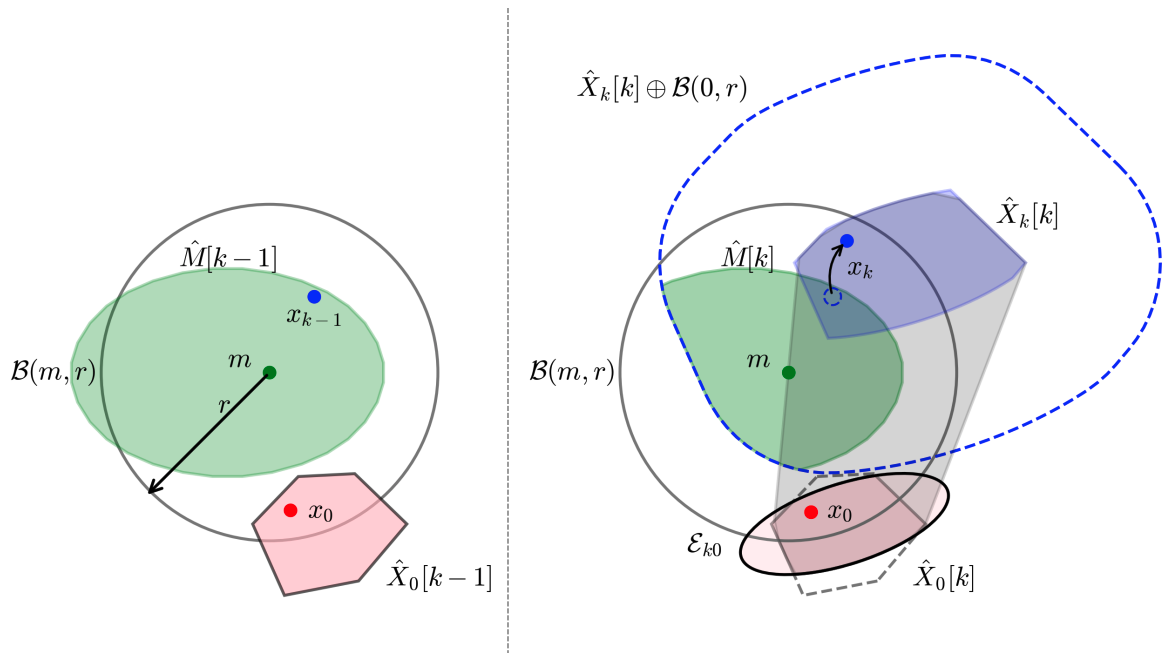
Active Localization of Unstable Systems with Coarse Information
Ege Yuceel, Daniel Liberzon, Sayan Mitra ACM International Conference on Hybrid Systems: Computation and Control (HSCC), 2026 (Best Paper — Foundations Track) Paper TL;DR: We explore the fundamental limits of localizing an unstable system from only single-bit measurements, establishing when its state can be recovered at all. The proposed algorithm combines a set-based estimator with an active, Voronoi-based control law that steers the system toward informative measurements, making the state estimate converge exponentially fast. |
|
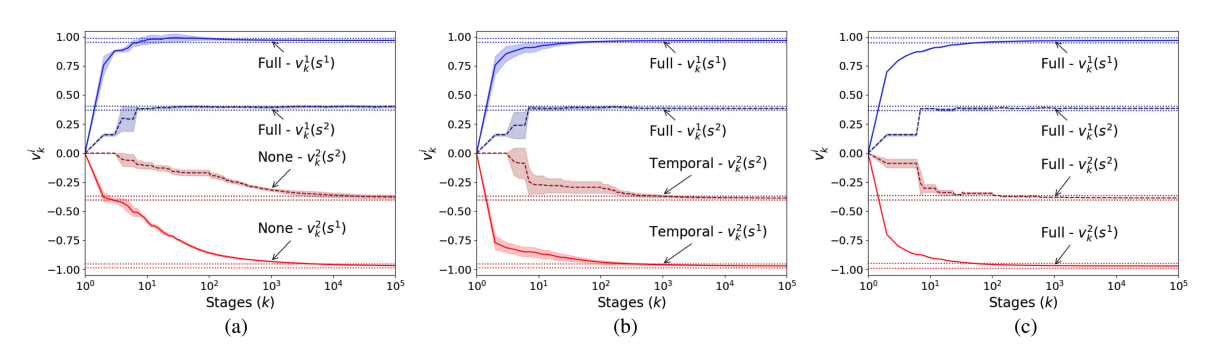
Convergence of Heterogeneous Learning Dynamics in Zero-sum Stochastic Games
Yuksel Arslantas, Ege Yuceel, Yigit Yalin, Muhammed O. Sayin IEEE Transactions on Automatic Control (TAC), 2025 Paper TL;DR: We propose a family of uncoupled, rational learning dynamics (including fictitious play) for zero-sum and stochastic games, and show they converge to equilibrium even when the two agents differ in learning rate, observation access, and model-based versus model-free updates. |
|
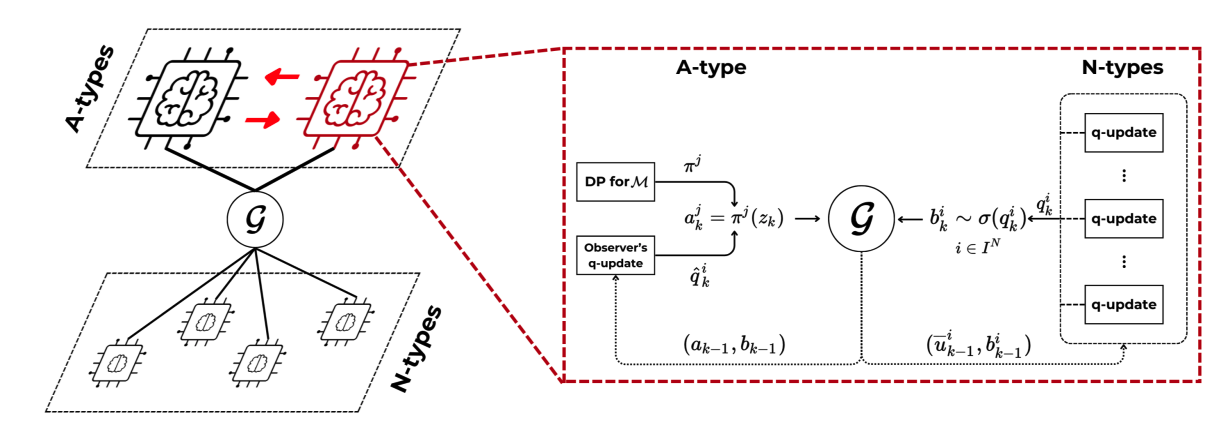
Strategizing against Q-learners: A Control-theoretical Approach
Yuksel Arslantas, Ege Yuceel, Muhammed O. Sayin IEEE Control Systems Letters (L-CSS), 2024 Paper TL;DR: We propose a control-theoretic approach for strategizing against Q-learners, modeling the repeated interaction as a dynamical system whose state tracks the opponents' Q-estimates and using quantization to handle its continuous state, quantifying how much a strategic agent can exploit naive learners. |
|
The source code of this website has been taken from here. |